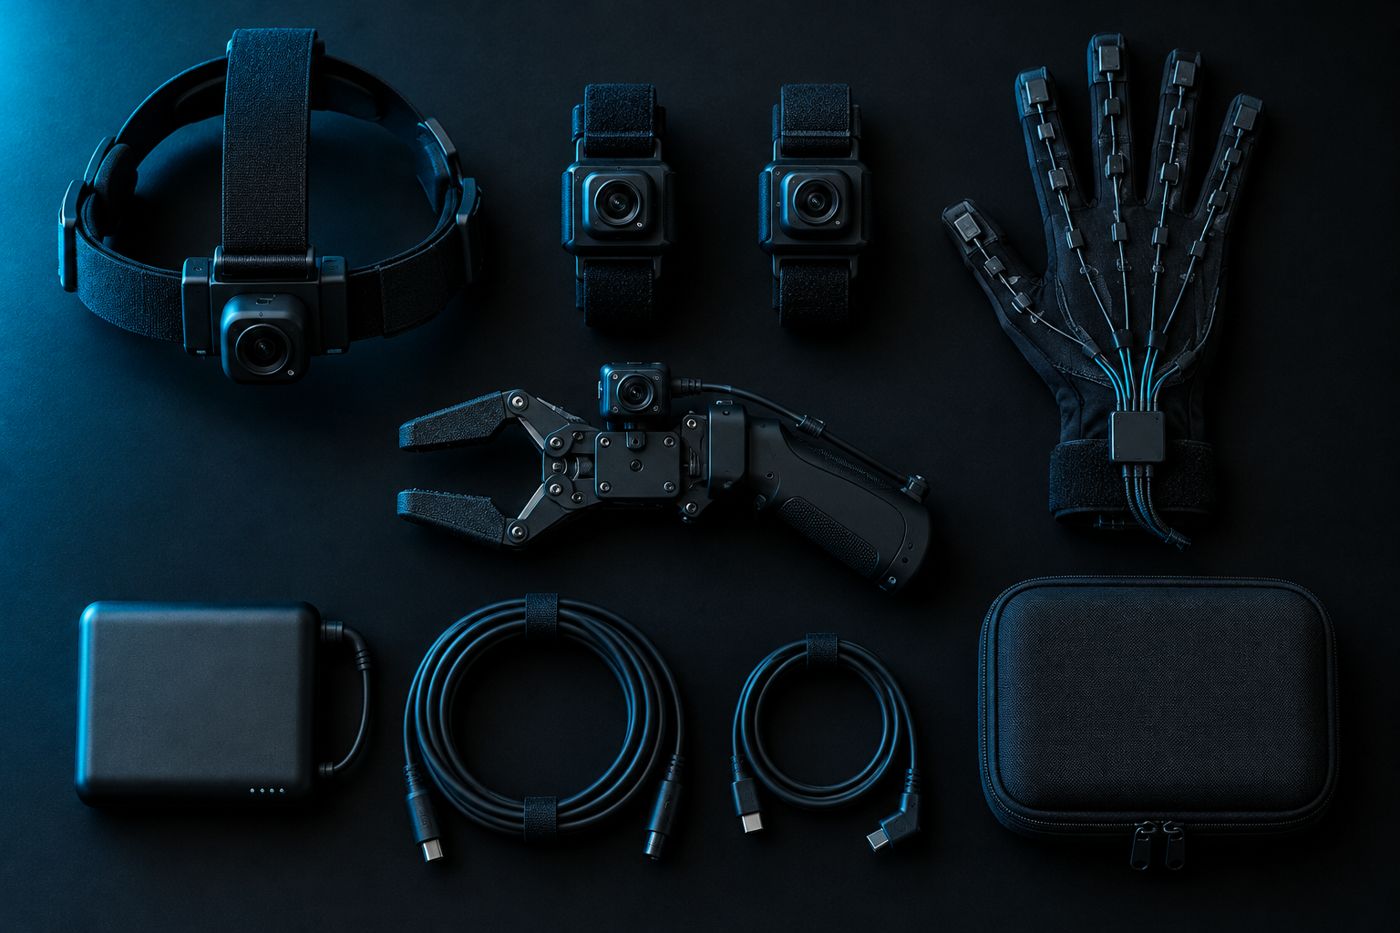
Multi-sensor robot training data (egocentric, wrist and gripper streams at 30 Hz), produced to buyer spec
- Where
- capture sites not stated; data stored in the EU
- Capacity
- 31 stations, 80+ operators, day and night shifts; 400+ h delivered a day
- Consent
- one consent signed per operator covering usage scope, with traceability for every session
LeRobot v3RLDSMP4JSON
Custom egocentric video datasets for embodied AI and robotics: synchronised multimodal human data from an instrumented rig, plus a contributor-worn 360 camera tier
- Where
- capture jurisdictions: US, Canada, UK, Germany, Netherlands, Poland, Portugal, Japan, South Korea, Singapore, Mexico, Brazil; 16 countries in total; contributors in any country may apply; contributor count not stated
- Capacity
- –
- Consent
- every participant signs a written commercial release before capture (release v3.2 covers commercial training use); bystanders de-identified or clip discarded; withdrawal from future sessions and deletion of undelivered recordings; delivered recordings cannot be recalled from a licensee
LeRobotRLDSHDF5WebDatasetzarr
Physical AI data engine: teleoperated demonstration and egocentric data collection, multi-modal labelling and expert feedback, evaluation, datasets
- Where
- collection network: data factories, residential collectors, commercial or industrial in-field deployments; countries not stated; optional onshore data processing
- Capacity
- 1000+ hours of diverse demonstration data collected and uploaded to Scale's platform every day (network claim)
- Consent
- GDPR and CCPA support stated; consent process not stated
Robot data services: teleoperation, egocentric and UMI collection, task-ready robot-learning datasets, hardware-synced demonstrations and a data marketplace (42 datasets, 20k+ hours stated)
- Where
- San Francisco and Allston MA labs; 'US-based' engineering support; capture countries not stated
- Capacity
- marketplace shows 42 datasets and 20k+ hours (stated)
- Consent
- –
LeRobotRLDSHDF5
Collects real-world human movement data for robot training: wearable or phone head-mount capture by people and by businesses' workers, delivered as annotated datasets
- Where
- 'Collecting across 3 continents'; countries not stated
- Capacity
- –
- Consent
- no formal consent process described; privacy rules (avoid faces, screens, private documents); narration only when chosen; contributors can preview before upload; bystander consent not described
Large-scale head-mounted egocentric video and human demonstration data collection for robotics, with operations, annotation and QA
- Where
- operations in India, Japan, USA (footer)
- Capacity
- 10K+ hours of video per day; 1.5M+ workers; 1,000+ cities; 100+ environments; 1,000+ worksites (as stated; page also shows '0 cities' in one stat)
- Consent
- –
Arabic-first AI company: records and verifies real work (KLKT app, paid per accepted hour) for physical AI training data, speech data (Munsit) and voice agents (Agentix)
- Where
- footage from warehouses, kitchens, hotels and hospitals; GCC-based hosting and telephony; specific countries of operation not stated
- Capacity
- –
- Consent
- real jobs recorded with consent through KLKT, consent offered in 4 languages; workers paid for accepted hours; a person reviews every hour; withdrawal and retention not stated
Operator network that records first-person clips of real work with a DeepReach device, matched to buyer tasks; operators are paid per accepted task
- Where
- 'Data Partners in dozens of countries'; testimonials name Ecuador, USA, India, Thailand, Canada, Vietnam; no full list
- Capacity
- –
- Consent
- application, interview and resource verification, invitation, NDA before previewing up to five tasks; data consent specifically not stated
'Model-ready egocentric data for physical AI': first-party household and workplace video, custom egocentric collection, exocentric and paired ego/exo capture, robotics training data and annotation
- Where
- contributor network 'across Philippines and South Africa'; per-dataset capture country not stated
- Capacity
- –
- Consent
- 'Eligibility, consent, timing, training rights and delivery are confirmed in the written scope' (no process described)
Robotics and physical AI data collection across Latin America: head- or chest-mounted egocentric video, IMU, haptic and hand signals from real tasks, with consent and field support handled by Gesto
- Where
- 'across Latin America'; settings: homes, job sites, commercial kitchens, retail and hospitality, warehousing, workshops; specific countries not stated (Mexico programme mentioned)
- Capacity
- –
- Consent
- Gesto handles 'consent, contracts, scheduling, field support and payments'; participants learn protocol and kit before recording; every session checked against acceptance criteria; consent wording not stated
'Research and data engine for Physical AI': validation, processing and labelling across sound, sight, motion and touch (speech audio, first-person video, IMU, grip-force), in 20+ countries
- Where
- '20+ countries', 'in the field in 20+ countries across four continents'; HQ Bangalore and a US subsidiary; capture sites not stated
- Capacity
- –
- Consent
- –
LeRobot v3RLDSMCAPROS BagJSON
Data collection and labelling company (Dubai office) with egocentric and robotics data: head-mounted and wearable first-person video and sensor data for humanoid robotics, AR/VR and foundation models
- Where
- office Dubai, UAE; 1,100+ labelers (one section says 1,000+); data collection runs on Prolific; sourcing countries not stated (synthetic passports cover 100+ countries)
- Capacity
- egocentric dataset 4,050 hours; Robotics category 5,050+ hours across 4 datasets (stated)
- Consent
- –
MP4
Records first-person work by contributors into annotated, training-ready robotics datasets; contributors earn per task in an app; businesses can bring their own workforce
- Where
- 'Selected regions' shown for contributor rates; country list not stated
- Capacity
- 109 open tasks shown (task count, not capacity)
- Consent
- –
Captures real-world data in Latin American factories, labs and job sites (program Cidria, first-person data collection), and deploys robots trained on it
- Where
- factories, labs and job sites in Latin America; specific countries not stated
- Capacity
- –
- Consent
- –
Vertically integrated physical-AI data collection: real working data (egocentric, head-mounted capture in factories) for research teams, off-the-shelf dataset or custom collection
- Where
- India named in text; 'Collection is starting in these countries for our next release' with countries shown only in image filenames (Brazil, Colombia, Argentina, Kenya, Ghana, Turkiye, Indonesia, Vietnam, Philippines, Mexico) (inferred from filenames, not stated)
- Capacity
- –
- Consent
- –
Large-scale real-world robot and human data for embodied AI: egocentric data with hand and body pose and subtask annotation, and robot trajectories collected in real workplaces through industry partners
- Where
- 'real workplaces' through 'our network of industry partners'; careers pages list Singapore, Johor Bahru and San Francisco as job locations (not capture sites)
- Capacity
- –
- Consent
- –
Custom egocentric video and robot demonstration data: household and workplace egocentric datasets with task, action and object labels, UMI bimanual and teleoperation data for robotics and physical AI
- Where
- –
- Capacity
- –
- Consent
- –
Data and deployments infrastructure for physical AI: scales human video and sensor data, runs an OTS (off-the-shelf) catalogue and robot deployments
- Where
- –
- Capacity
- –
- Consent
- –
Physical AI data collection and annotation: egocentric collection from wearable rigs, iPhones and GoPros, teleoperation, real-world capture for simulation and world models, multimodal and video annotation
- Where
- capture environments: household, commercial, industrial, retail, outdoor; capture countries not stated
- Capacity
- –
- Consent
- –
'Data Engine' for embodied AI: end-to-end pipeline of data gathering, teleoperation, labelling and monitoring; datasets of real tasks recorded where they happen
- Where
- data stored in the cloud; can integrate with buyer infrastructure; capture countries not stated
- Capacity
- –
- Consent
- –
Data engineering and annotation firm with a Physical AI Data Collection service: real-world training data for robotics, VLA models, world models, wearables and embodied AI
- Where
- '20+ global delivery locations' (not named); physical AI collection sites not stated
- Capacity
- –
- Consent
- –
Egocentric data vendor (roboticsmap listing: annotated video and hand tracking); the home page read returned only its title 'Real-World Experience for Physical AI'
- Where
- –
- Capacity
- –
- Consent
- –
'The data and deployment layer for physical AI': mobile app for environment and task capture, the Egoverse first-person dataset, dataset access and commissioned collection
- Where
- 'Explore human data from around the world'; countries not stated
- Capacity
- –
- Consent
- –
Expert-demonstrated data for robotics labs: skilled-task demonstrations (repair, assembly, logistics, field operations) and robot data-factory capture, alongside broader AI training data
- Where
- data factory with controlled robotics environments; capture countries not stated
- Capacity
- –
- Consent
- –
'The Real-World Data Engine for Physical AI': teleoperation, egocentric capture, robot trajectories, RGBD and multimodal annotation for robotics companies
- Where
- 8 global locations: Phoenix, Mesa and Scottsdale (AZ, US); Karur, Coimbatore and Chennai (Tamil Nadu, India); 2,200+ specialists
- Capacity
- –
- Consent
- –
'The Training Data Platform for Physical AI' (page title); roboticsmap lists it as real-world egocentric data infrastructure based in Dubai; the home page read gave only the title
- Where
- –
- Capacity
- –
- Consent
- –
Teleoperation and wearable-sensor robot data collection (roboticsmap listing); the home page did not load in the read (the site redirects to a www host that does not resolve)
- Where
- –
- Capacity
- –
- Consent
- –