Tactile and force data for robots
Touch and force are what video misses in contact-rich tasks. Pick a sensor to see what it records, what to spec and who offers it.
Pressure across the palm and fingers while a person does the task.
- Number and layout of sensing cells
- Sampling rate, stated in Hz
- Sync with the video frames
- Calibration and units (kPa or N)
- Glove size range and wear checks
- DataClue…demonstrations (UMI gripper, teleoperation, stereo multi-camera, tactile glove); multimodal; eye tracking and RGB-D; BCI RGB video 30/60 fps,…
- Datoric…teleoperation (video, states, actions, robot and sensor configuration); tactile glove; stereo manipulation; paired egocentric RGB and IMU RGB video;…
- Gesto Data…Latin America: head- or chest-mounted egocentric video, IMU, haptic and hand signals from real tasks, with consent and field support…
Tactile glove: Pressure across the palm and fingers while a person does the task. Spec: Number and layout of sensing cells; Sampling rate, stated in Hz; Sync with the video frames; Calibration and units (kPa or N); Glove size range and wear checks. Suppliers: DataClue, Datoric, Gesto Data.
Fingertip tactile: Contact on the gripper’s fingertips: where it touches, how hard, and when it slips. Spec: Sensor type: optical, capacitive or resistive; Image size or cell count per fingertip; Sampling rate and sync with robot state; Raw images or processed contact maps; Slip and failure episodes kept. Suppliers: Datoric, Pixelstwo, Claru, Paxini.
Grip force: How hard the hand or gripper squeezes over time. Spec: Force range and resolution; Sampling rate; Which finger or jaw it measures; Units and zero offset per session. Suppliers: Humyn Labs.
Wrist force/torque: Six numbers at the wrist: three forces and three torques, for pushing, inserting and wiping. Spec: Sensor model and mounting; Rate, stated in Hz; Gravity and tool compensation; Frame of reference for each axis; Sync with joint states and video. Suppliers: Physical Data, Uber AI Solutions.
Pressure arrays: A grid of pressure readings under an object, a hand or a foot. Spec: Grid size and cell pitch; Pressure range; Sampling rate; Calibration method. Suppliers: DataClue, Physical Data.
Supplier mentions come from each firm’s own site. A mention is not a dataset in stock, so ask for a sample.
Three open datasets, and whether you may use them commercially.
Check the licence before you train a product on it.
| Dataset | Sensors | Size | Licence |
|---|---|---|---|
| TaF-Dataset | Six-axis force/torque (ground truth), 12x12 pressure array, GelSight Mini and a vision-based tactile sensor | 408 sequences, 3,592 episodes, 10 million synced frames, 41.5 GB | Commercial use allowed MIT |
| FreeTacMan | Two optical tactile sensors, one per fingertip, plus a wrist camera. No force/torque sensor | 6,228 trajectory groups across 45 tasks in this copy | Commercial use allowed MIT |
| RH20T | Six-axis force/torque; fingertip tactile at 200 Hz in one of 7 robot setups | 110,000+ sequences across 7 robot configurations | Split by scene Scenes 1 to 5 CC-BY-SA-4.0; scenes 6 to 10 CC-BY-NC-4.0 |
As stated on each dataset page, read 17 Nov 2026. RH20T’s licence is read from a mirror page.
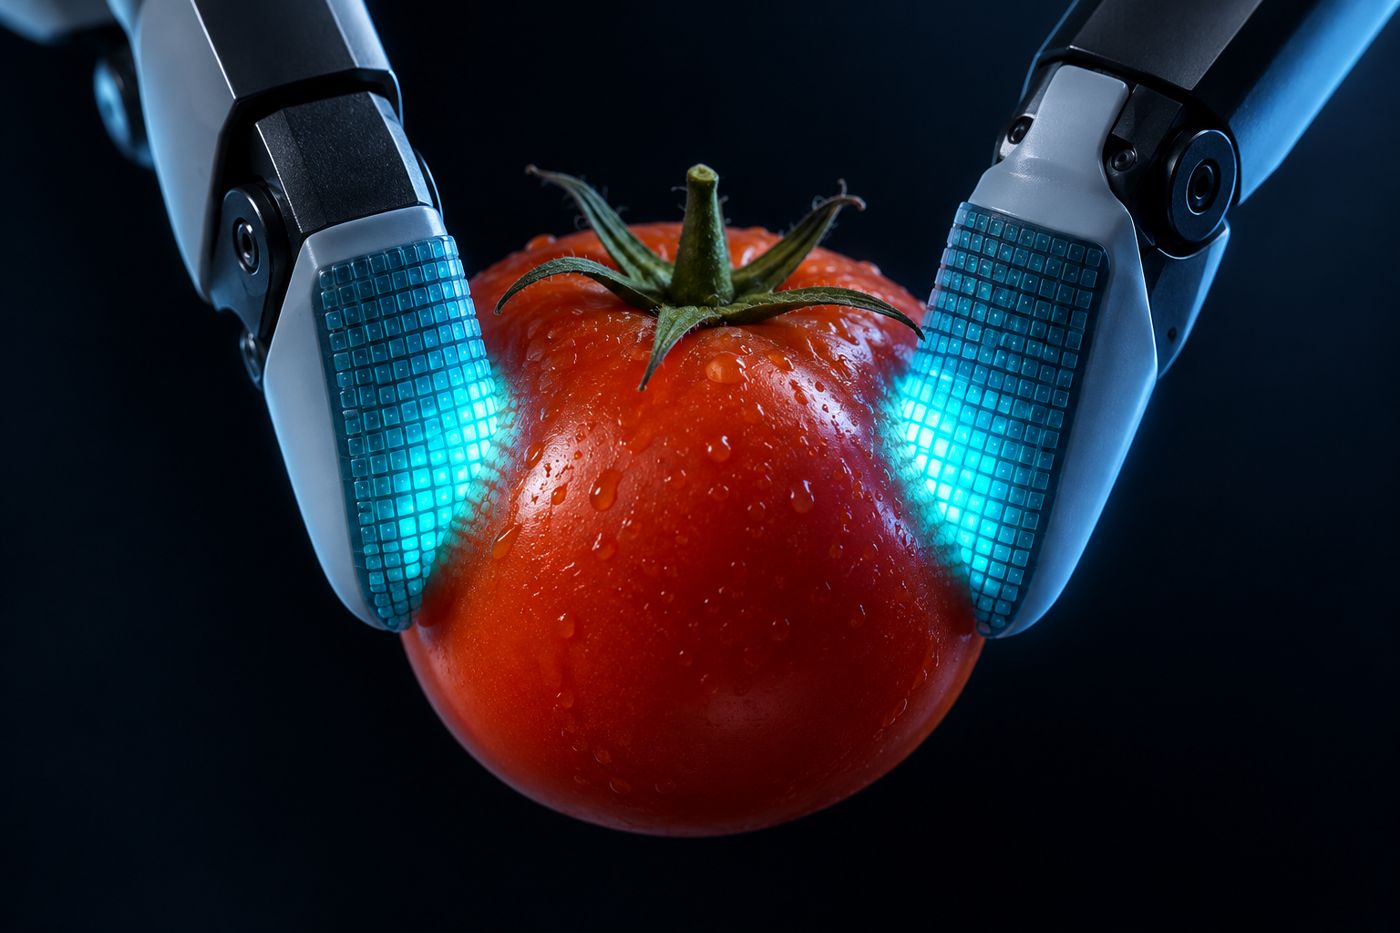
Touch data has to line up with everything else.
- One clock. Touch, force, joint states and video stamped against the same clock.
- Ground truth. Optical tactile sensors estimate force; a wrist sensor measures it. Say which you need.[1]
- Contact episodes. Grasps, slips, insertions and failures, labelled.
- Raw and processed. Ask for both, so you can re-process later.
Spec your touch data.
Tell us the sensor, the task and the volume. We find suppliers that can record it on your setup.
Nothing goes to a supplier without your yes.
Questions
Who sells tactile and force data?
A handful of collectors list touch, grip force or force/torque among their sensors. Most quote per project, so ask for a sample first.
Are there free tactile datasets?
Yes. TaF-Dataset and FreeTacMan are MIT licensed. RH20T allows commercial use only in some scenes.
Do optical tactile sensors measure force?
They estimate it from images. If you need measured force, ask for a force/torque sensor in the rig.
What does tactile data cost?
None of the firms on our list publishes a price for touch or force data.
Spec your touch data.
Send one spec. We find suppliers that can record it.
[+] Sources
- FreeTacMan dataset page warns its optical tactile data is not ground-truth force. huggingface.co/datasets/Voxel51/FreeTacMan. Read 17 Nov 2026.
- TaF-Dataset: huggingface.co/datasets/jiamig/taf-dataset. RH20T (mirror): roboticscenter.ai/datasets/rh20t. Read 17 Nov 2026.
- Supplier mentions come from each firm’s own public site, read 16 Nov 2026. Claru and Paxini were read on 17 Nov 2026.